Robotics / Future concept
Walking spider robot workshop
This future robotics workshop takes inspiration from quadruped and spider-style designs. It covers servo control, joint movement, and walking patterns using a microcontroller and printed body and leg parts. Robot dimensions, leg count, and the final design remain TBD.
LEARNING TOPICS
Planned activities
- 01Control servo positions and test individual joints.
- 02Coordinate joint movements into a walking pattern.
- 03Test balance and movement in a 3D printed robot design.
HARDWARE
Proposed components
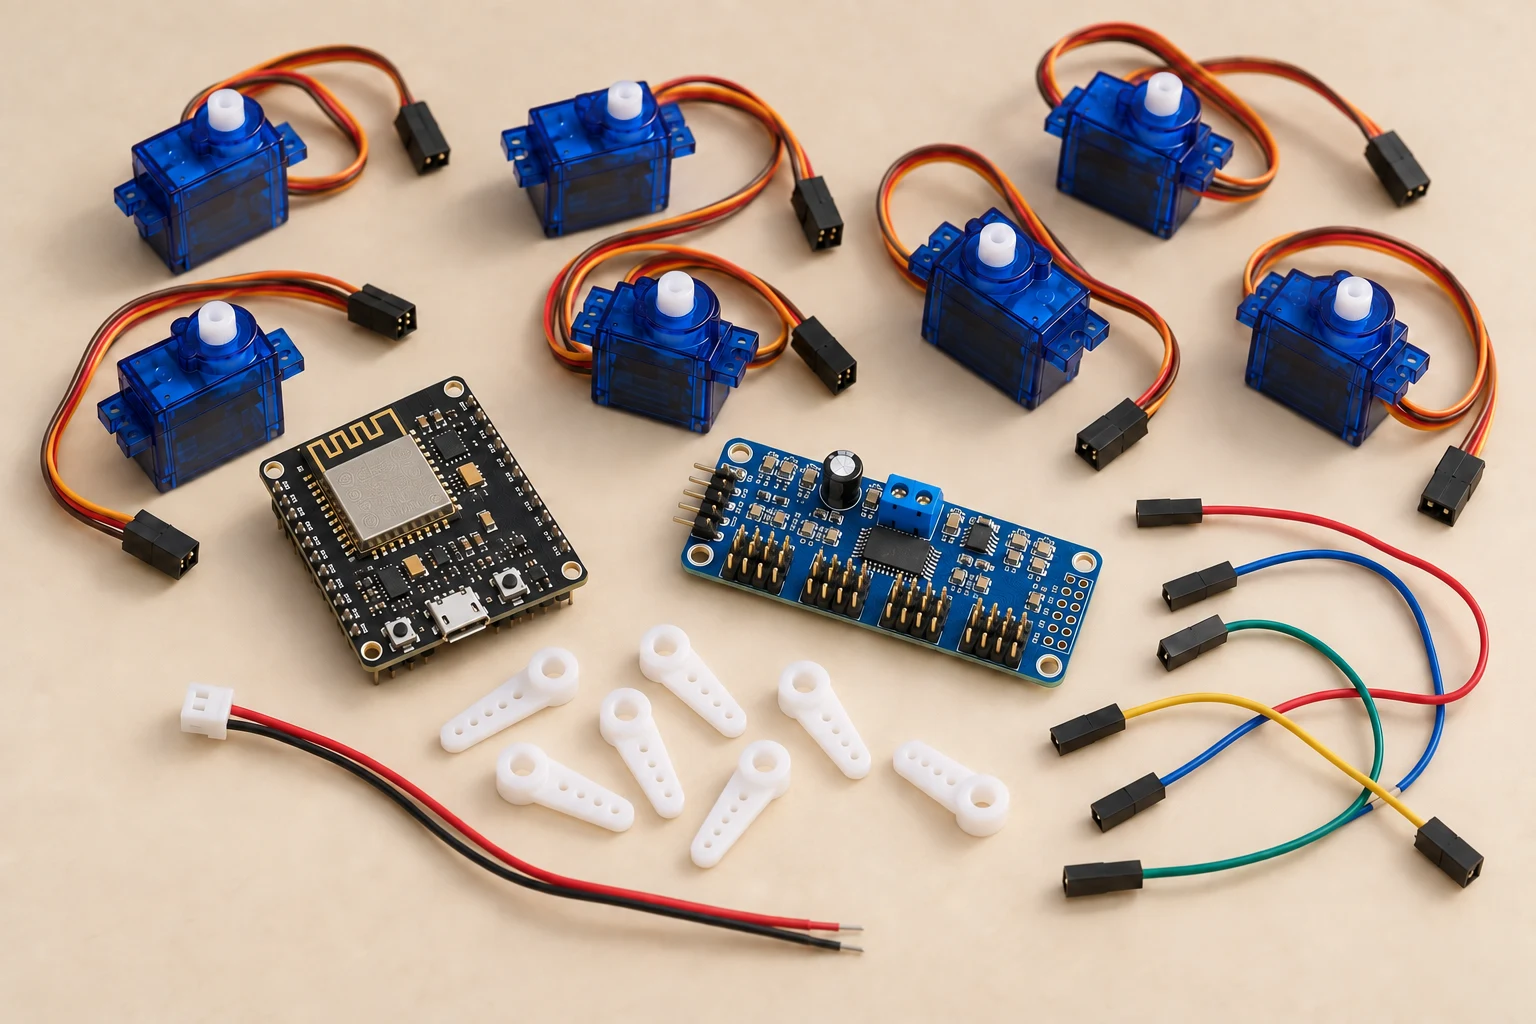
Proposed electronics: ESP32 development board, PCA9685 servo driver, positional hobby servos, servo horns, Dupont jumper wires, and JST connectors. Printed body and legs will be shown in future build photography. Servo count, dimensions, power system, and final kit contents TBD.
Possible extensions
The core concept focuses on servo control and coordinated movement. AI or TinyML may be considered after the mechanical design is established.
Experience requirements, supplied equipment, kit contents, and take-home arrangements TBD.
Project inspiration
Reference videos for the concept. The final Botspot build may differ.
Watch reference 1 on YouTube