Robotics / Planned workshop
3D Printed Omnidirectional Rover
Explore the electronics and movement control behind an omnidirectional rover. Connect the controller and motor drivers, coordinate four geared motors, and test movement commands. The planned build uses a 3D printed enclosure and two 18650 cells; the final mechanical design remains TBD.
LEARNING TOPICS
Planned activities
- 01Connect a microcontroller, motor drivers, and four geared motors.
- 02Coordinate motor directions for forward motion, turning, and sideways movement.
- 03Test movement and fit the electronics into the printed rover design.
HARDWARE
Proposed components
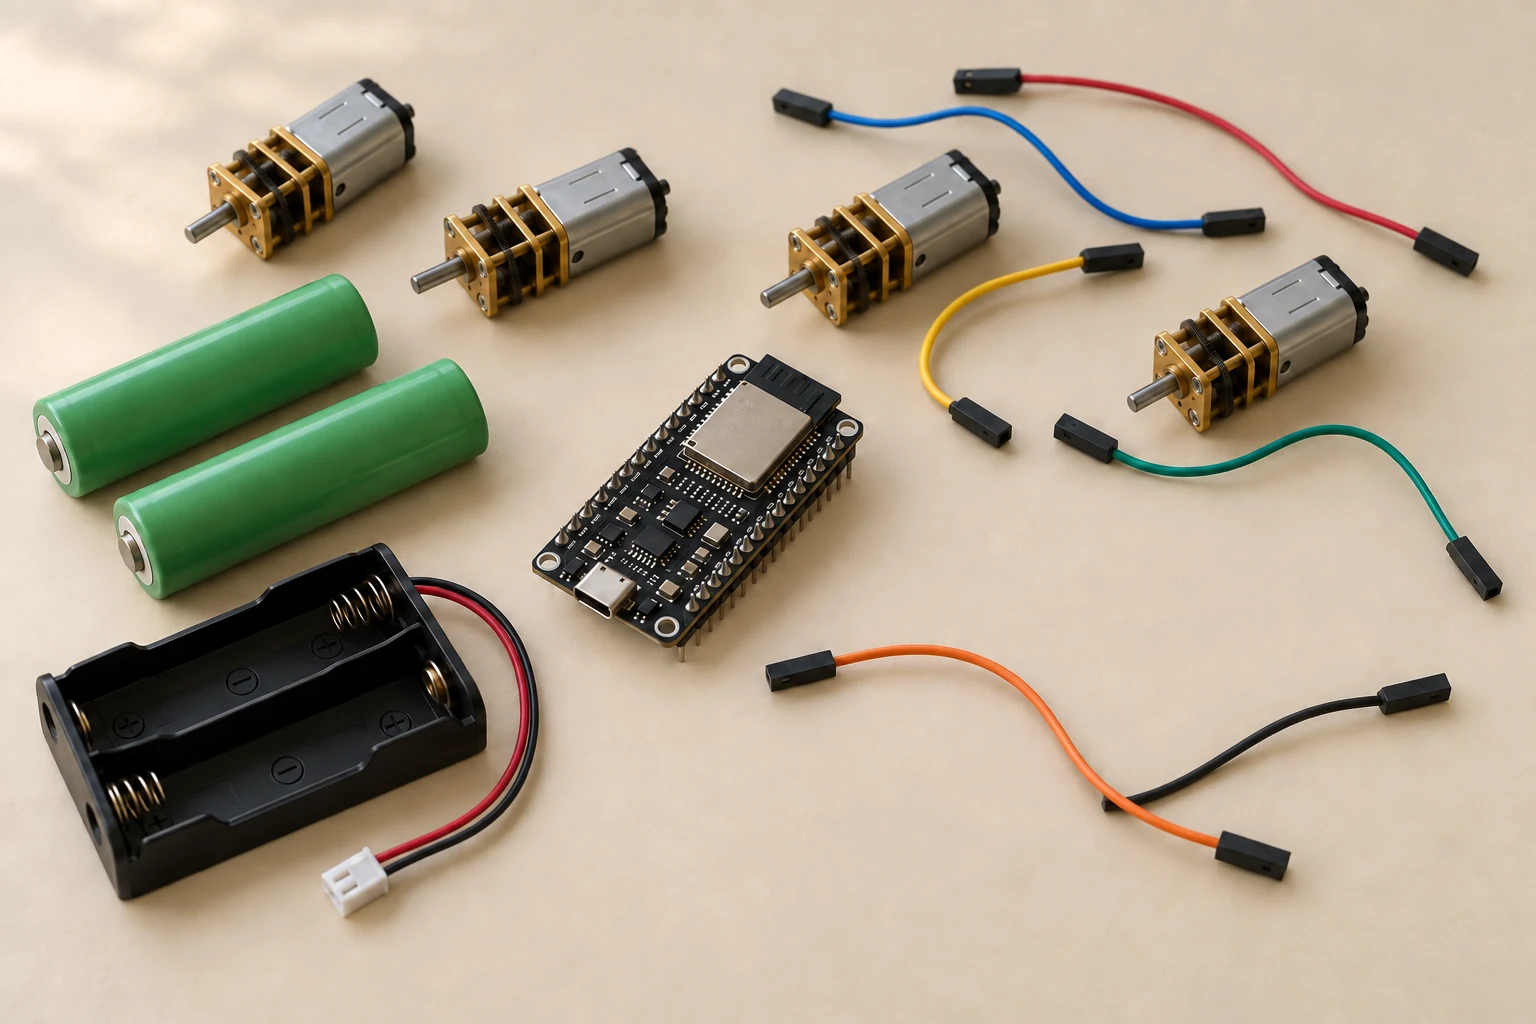
Proposed electronics: ESP32 development board, two dual motor drivers, four N20 geared motors, two 18650 cells and holder, Dupont jumper wires, and JST power connectors. Omnidirectional wheels and printed enclosure will be shown in future build photography. Final kit contents TBD.
Possible extensions
Sensor-based control or TinyML may be added in a future version. The planned core topics are wiring, programming, and motor control.
Experience requirements, supplied equipment, kit contents, and take-home arrangements TBD.